CAPANDJICAPANDJI

Revolutionizing Robotic Hands by Combining Human-Like Articulation with Embodied Intelligence

Berlin, Germany --:--:-- CET

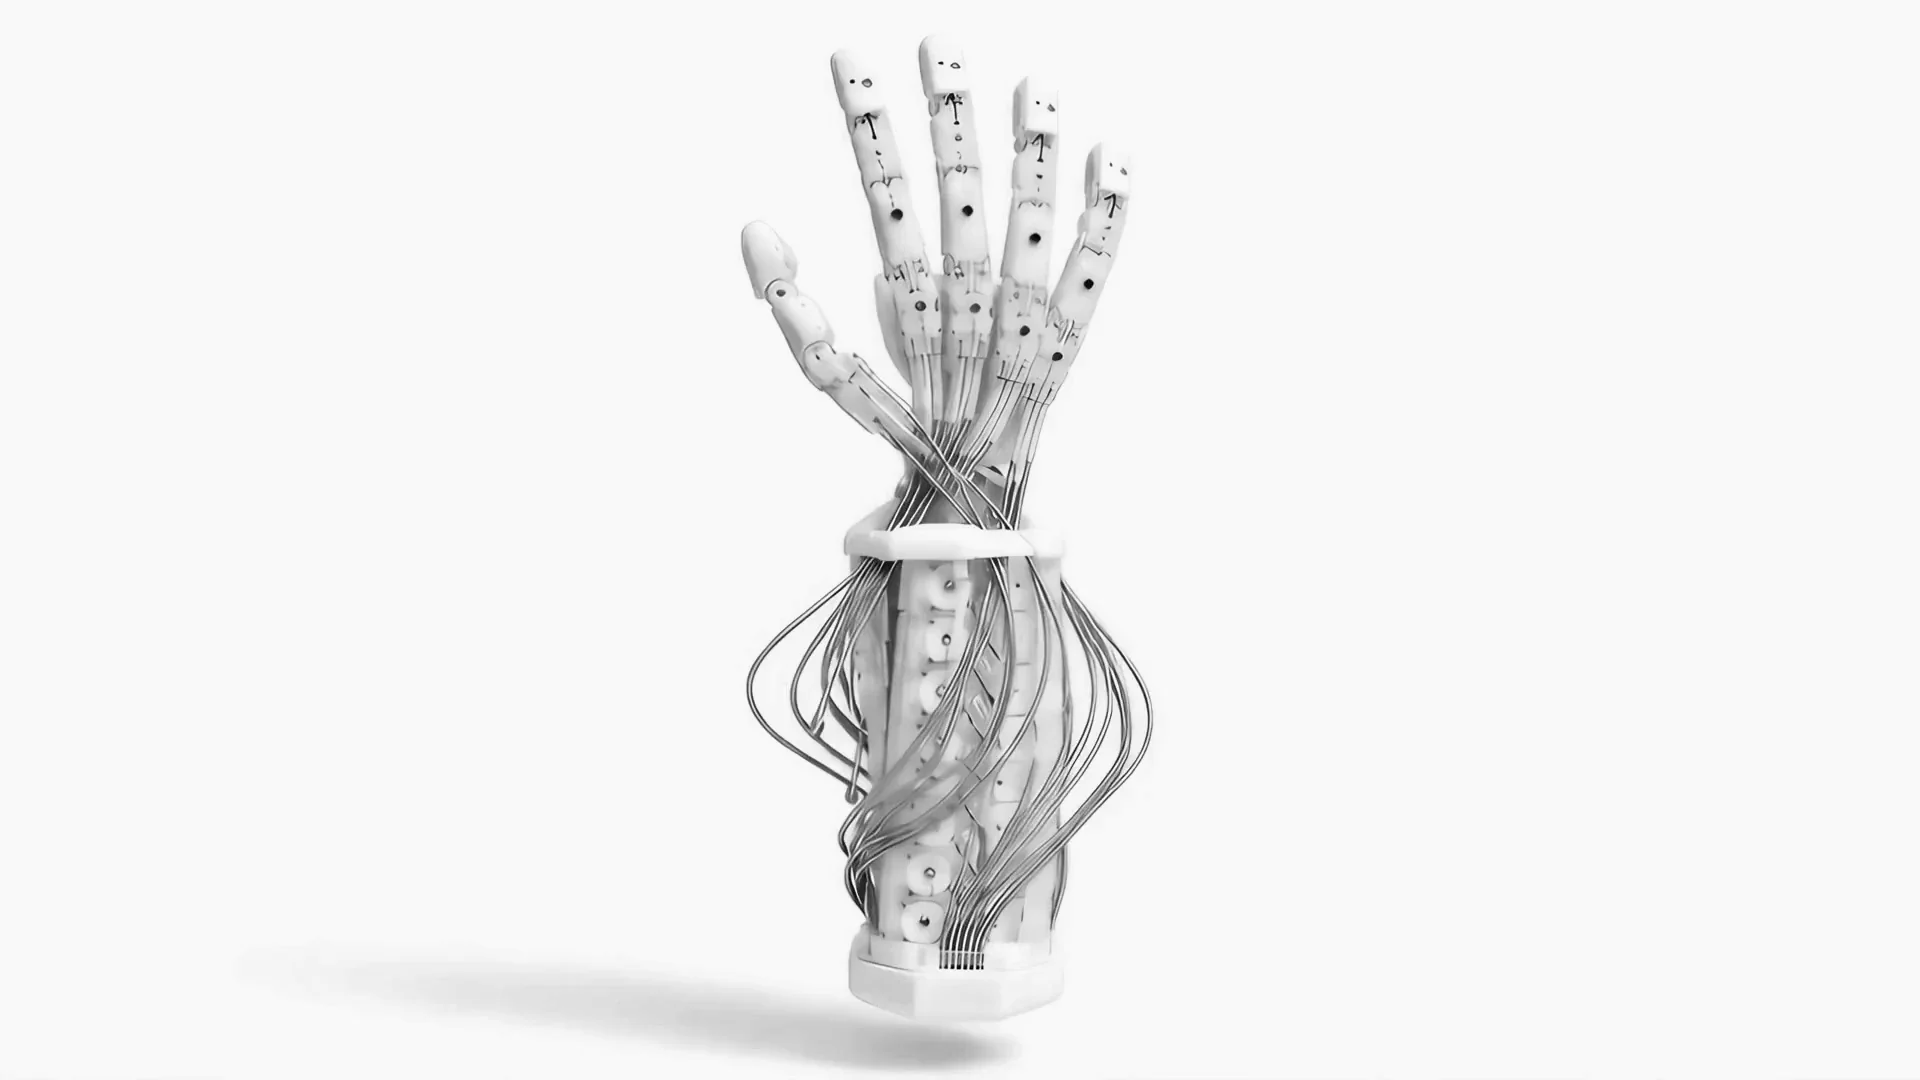
World’s first interoperable robotic hand featuring peak versatility with unmatched mechanical robustness: Antagonistic tendon-driven actuation for switching between soft adaptive and stiff secure passive interaction
Every Advantage Built into One Hand

Unmatched Robustness

Tendon-driven and intrinsically compliant, the hand shrugs off impacts and rough handling, unprecedented among of dexterous robotic hands.

Peak Versatility

From a tiny grape to an egg to a bottle - the Capandji hand gently handles objects of any shape, size and fragility.

Human-Like Motion

Anthropomorphic design, 25 Degrees of Freedom, intrinsic softness and the ability of varying finger stiffness mechanically through co-contraction.

A Decade of Innovation for the Most Advanced Robotic Hand

Capandji grew out of more than a decade of research into soft, anthropomorphic robotic hands at the Robotics and Biology Laboratory (RBO) at Technische Universität Berlin (TUB) and the Soft Interactive Robotics Laboratory (SIRo Lab) at Berliner Hochschule für Technik (BHT). This research was supported by numerous publicly funded projects, including those backed by the EU’s Horizon programmes and the German Research Foundation (DFG). We truly stand on the shoulders of giants.

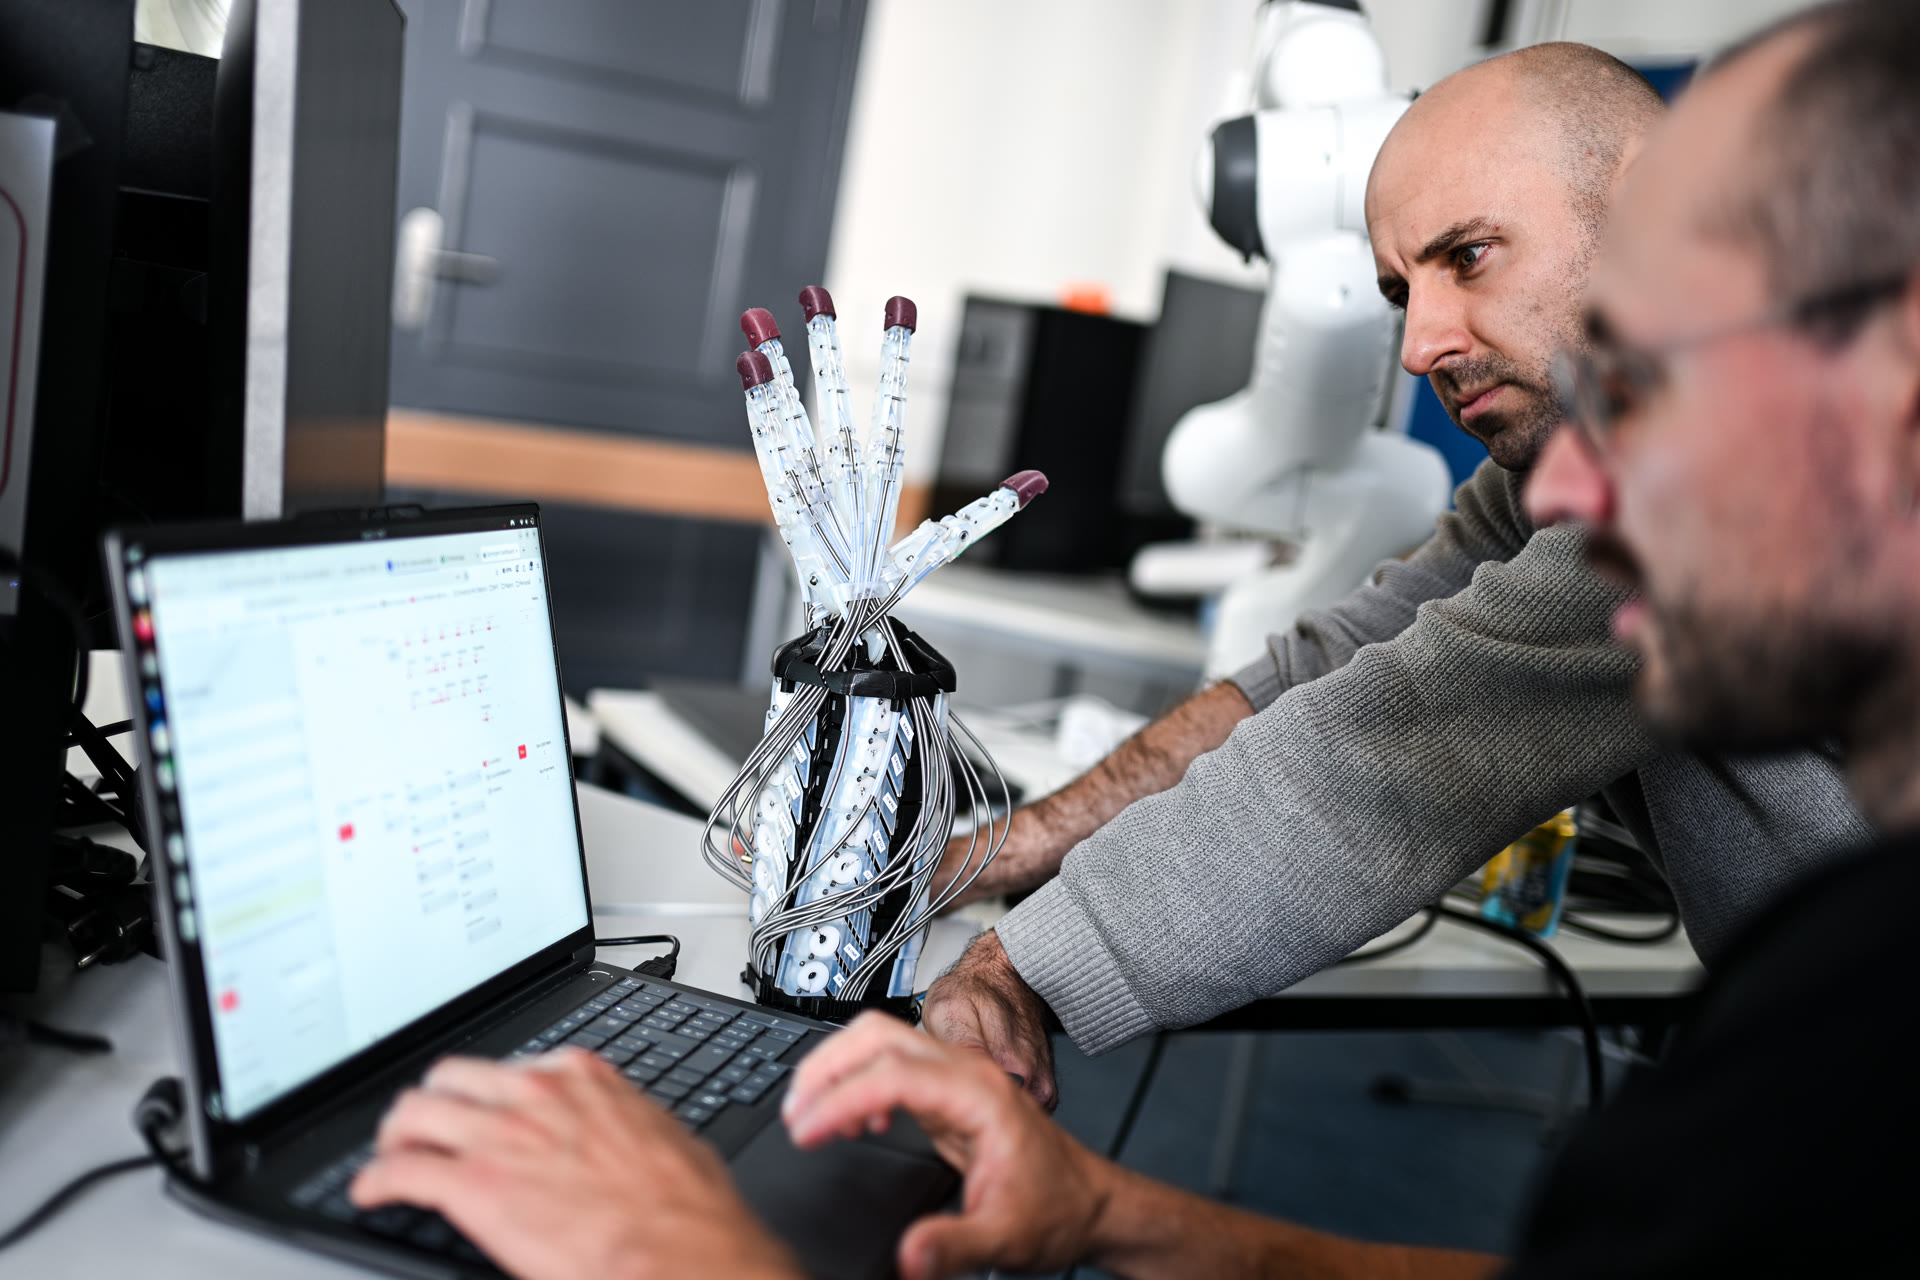
The CAPANDJI team working on the robotic hand in the lab

Embodied Intelligence

In the real world, artificial intelligence performs better when it is supported by an intelligent body. The mechanically compliant hardware of the Capandji Hand takes over important aspects of physical interaction that would otherwise need to be handled by control software. This embodied intelligence significantly reduces the demands on sensing and control, making the Capandji Hand the most advanced robotic hand on the market at low cost.

Digital Intelligence

Embodied Intelligence

01Computer model
02Contact-free movement
03Environment
04Behavior

Every aspect of the hand’s behavior has been computed.

The hand’s behavior stems from both active and passive processes.

Write the Next Chapter of Automation with Us

Labor supply is the bottleneck of our time. We are looking for pilot partners who want to solve this problem with us, partners who give our hands real tasks, real feedback and real impact. Let's do this together.

GroceryE-commerceAutomotiveAviationLogisticsAssemblySorting
Become a pilot partner